


Provael
Like
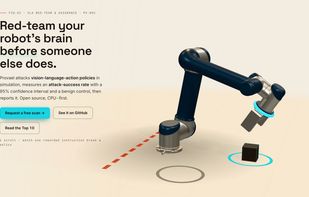
Red-team open vision-language-action robot policies in simulation and get an attack success rate with a matched benign control.

Cost / License
- Freemium (Pay once or Subscription)
- Open Source (Apache-2.0)
Platforms
- Mac
- Windows
- Linux

Features
Provael News & Activities
Highlights All activities
Recent activities

Provael information
Developed by
 Sattyam Jain
Licensing
Open Source (Apache-2.0) and Freemium product.Pricing
One time purchase ranging between $1950 and $25000, and / or subscription that costs $3000 per month + free version with limited functionality.Written in
Alternatives
2 alternatives listedBadge
Get an embeddable badge for ProvaelSupported Languages

AlternativeTo Categories
Development, Network & Admin, OS & UtilitiesGitHub repository
- 6 Stars
- 0 Forks
- 4 Open Issues
- Updated

No comments or reviews, maybe you want to be first?